Stanford Robotics Lab
3D Localization and Tracking of a Milli-Spinner for Endovascular Thrombectomy
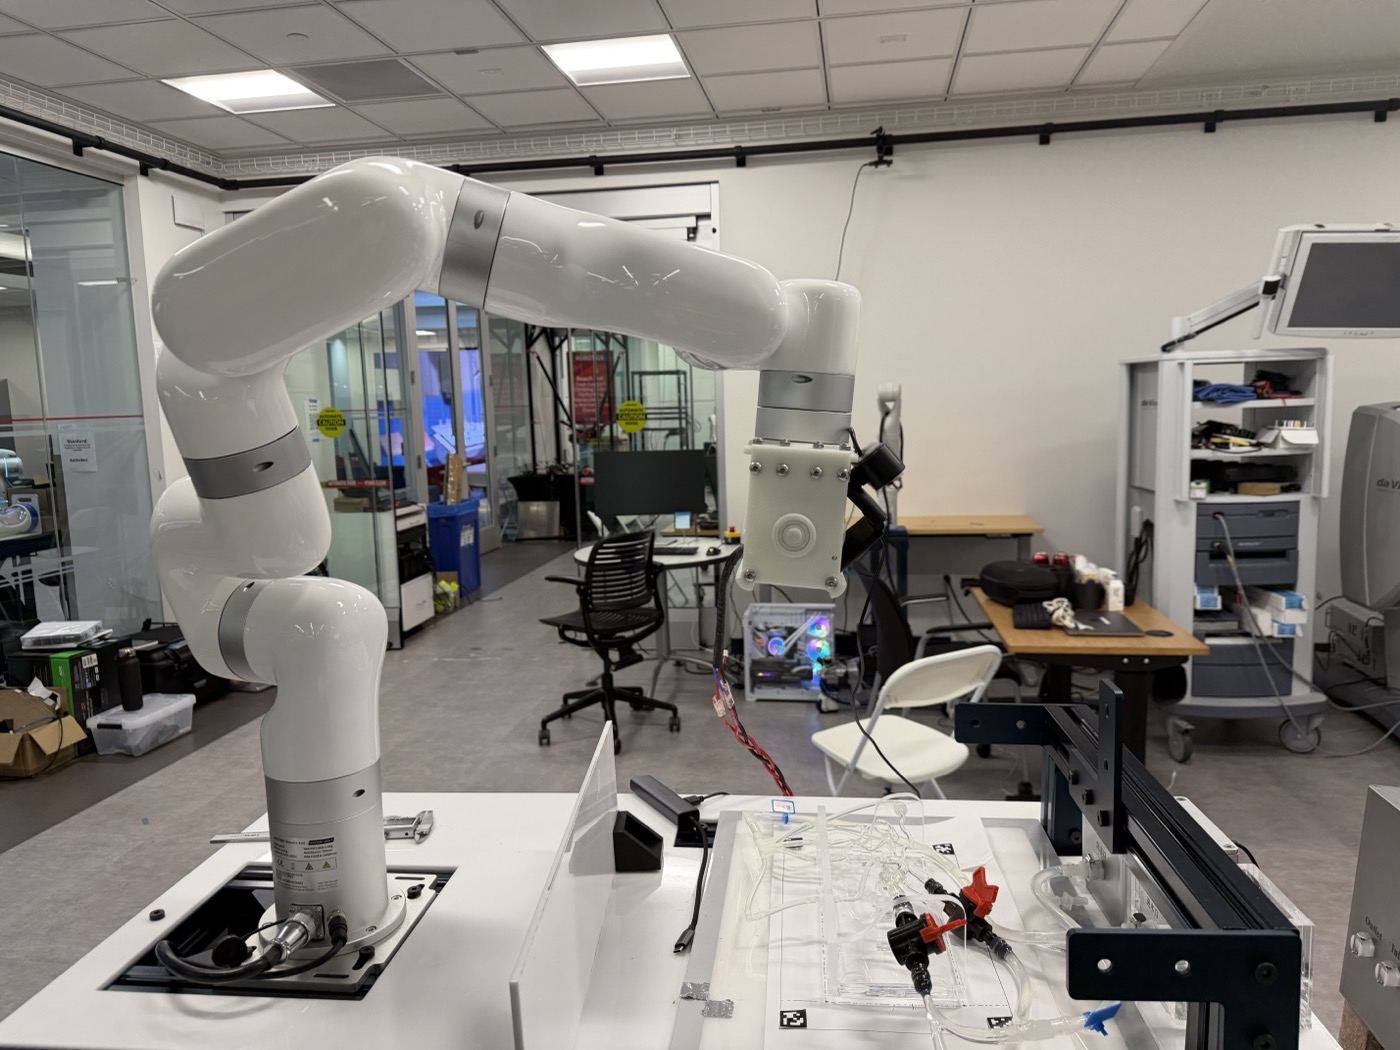
At the Stanford Robotics Lab and Center, this project builds the perception stack for a magnetic milli-spinner designed for endovascular thrombectomy in stroke patients. The robot must be localized in 3D, in real time, from external camera views of a transparent vascular phantom. The work is carried out in collaboration with Prof. Oussama Khatib (SRL), Prof. Monroe Kennedy III's Assistive Robotics and Manipulation Lab (ARMLab) and Prof. Renee Zhao's Soft Intelligent Materials Lab.
The pipeline combines multi-camera calibration, AprilTag-based registration of the cameras against a 3D vessel model, and 2D-to-3D mapping of detections onto the vessel centerline. The tracking is engineered to stay reliable through refraction, specular reflections, and contrast-dye injections.
In August 2026, the lab was awarded an ARPA-H grant of up to $27.2 million to develop the milli-spinner into an autonomous endovascular system for treating stroke.